diff_drive_robot
2024ROS 2 Jazzy · Gazebo Harmonic · SLAM Toolbox · Nav2 · Python
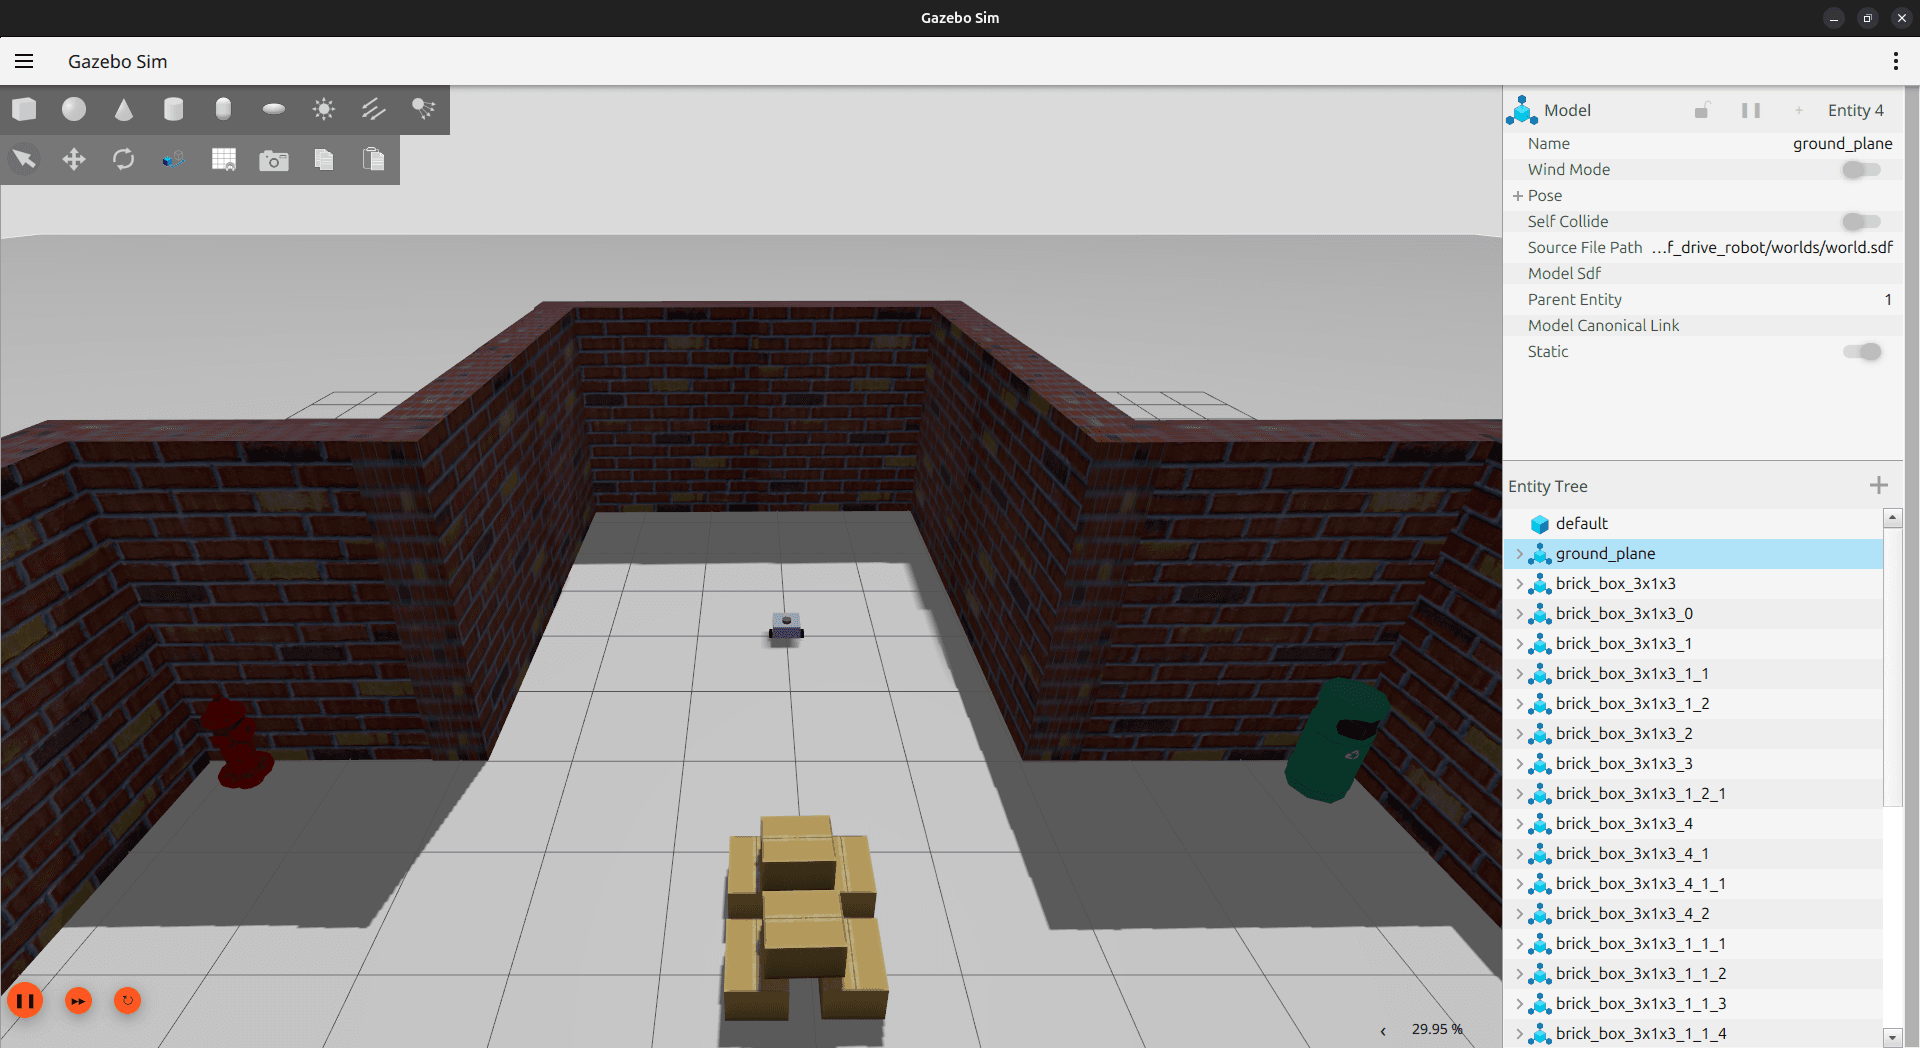
A ready-to-run simulation of a two-wheeled robot that spares people the days of setup usually needed before they can drive one. It ships the whole stack — robot description, lidar, keyboard control, SLAM mapping with EKF sensor fusion, and Nav2 navigation on ROS 2 Jazzy and Gazebo Harmonic — and has become a starting point for robotics learners and students worldwide.
so101_ros2
2026ROS 2 Jazzy · MoveIt 2 · ros2_control · Gazebo Harmonic · Python
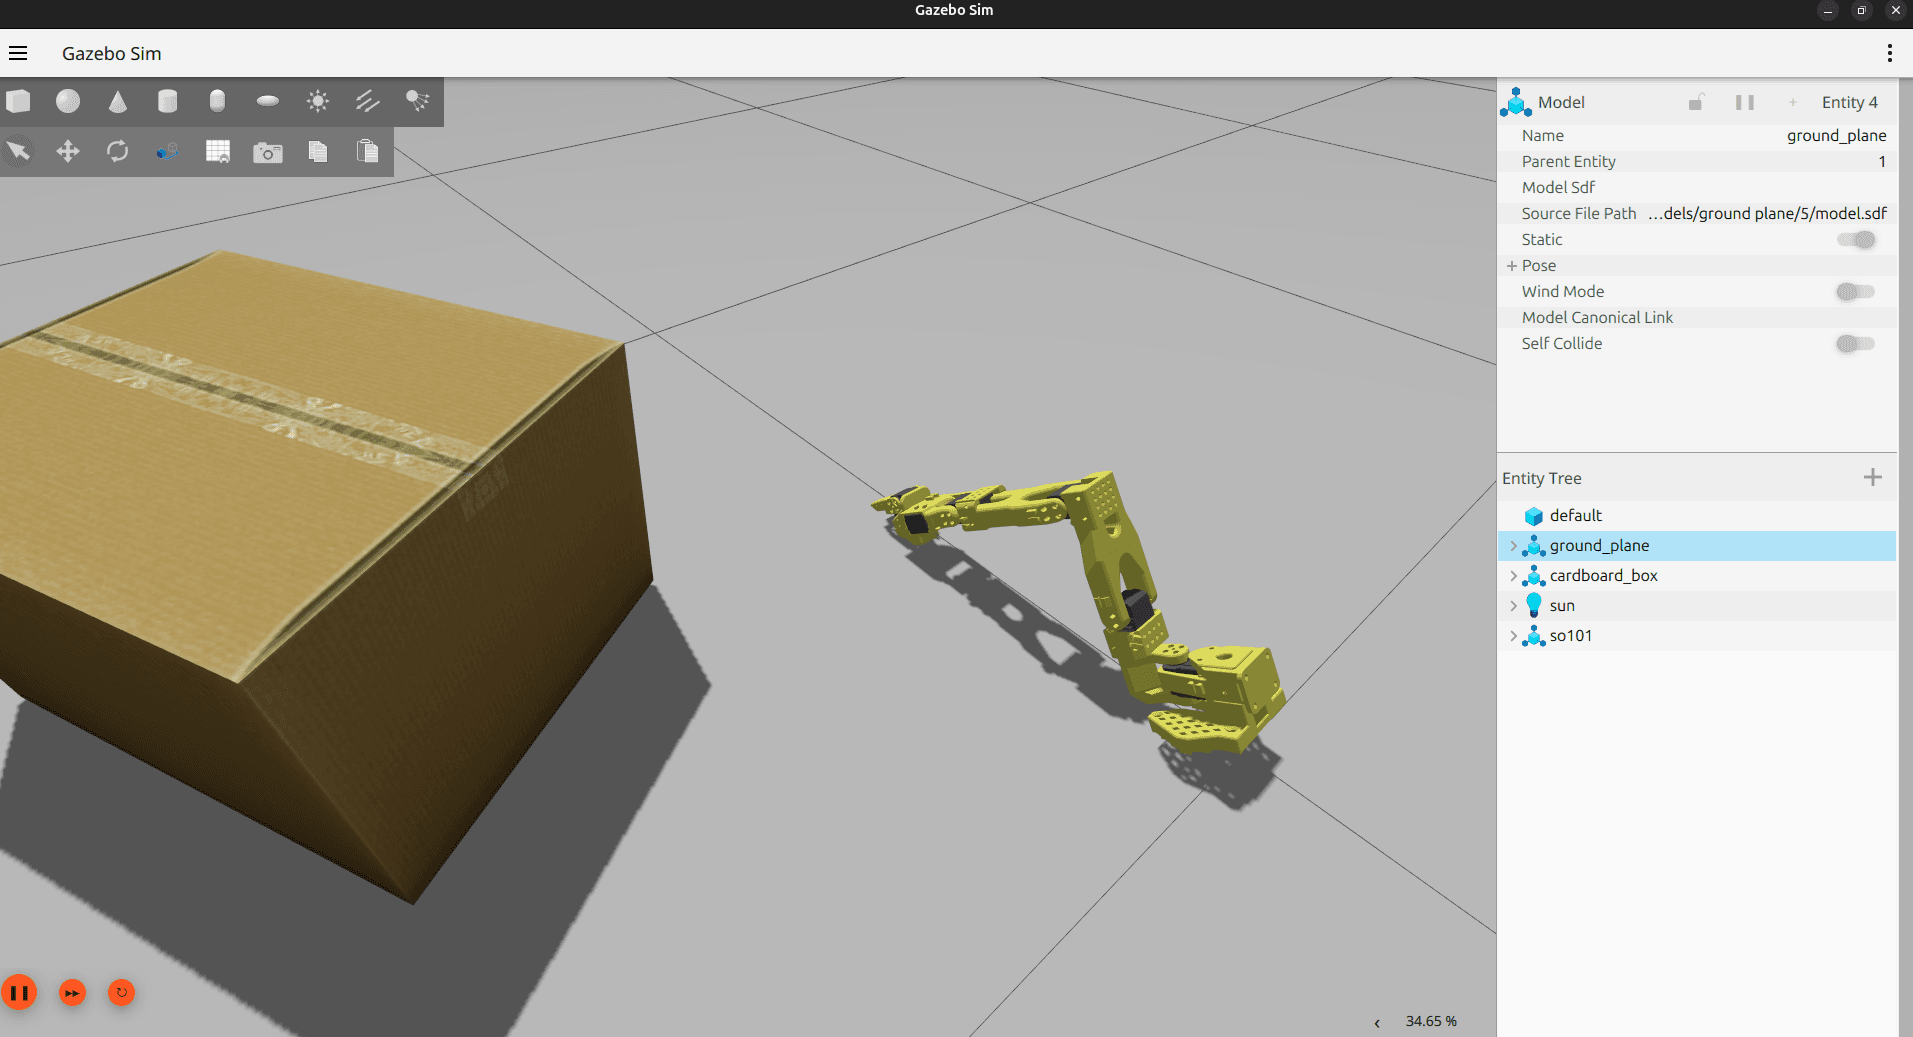
A complete control stack for the SO-101 robot arm, taking it from a 3D description to picking things up in simulation. It covers the arm's model and meshes, RViz visualization, ros2_control with trajectory control for the arm and gripper, and a pick-and-place world in Gazebo Harmonic, with MoveIt 2 motion planning and a real-hardware interface on the roadmap.
Self-Driving RC Car
2025Jetson Orin Nano · RealSense D435i · LiDAR · PID control · Python
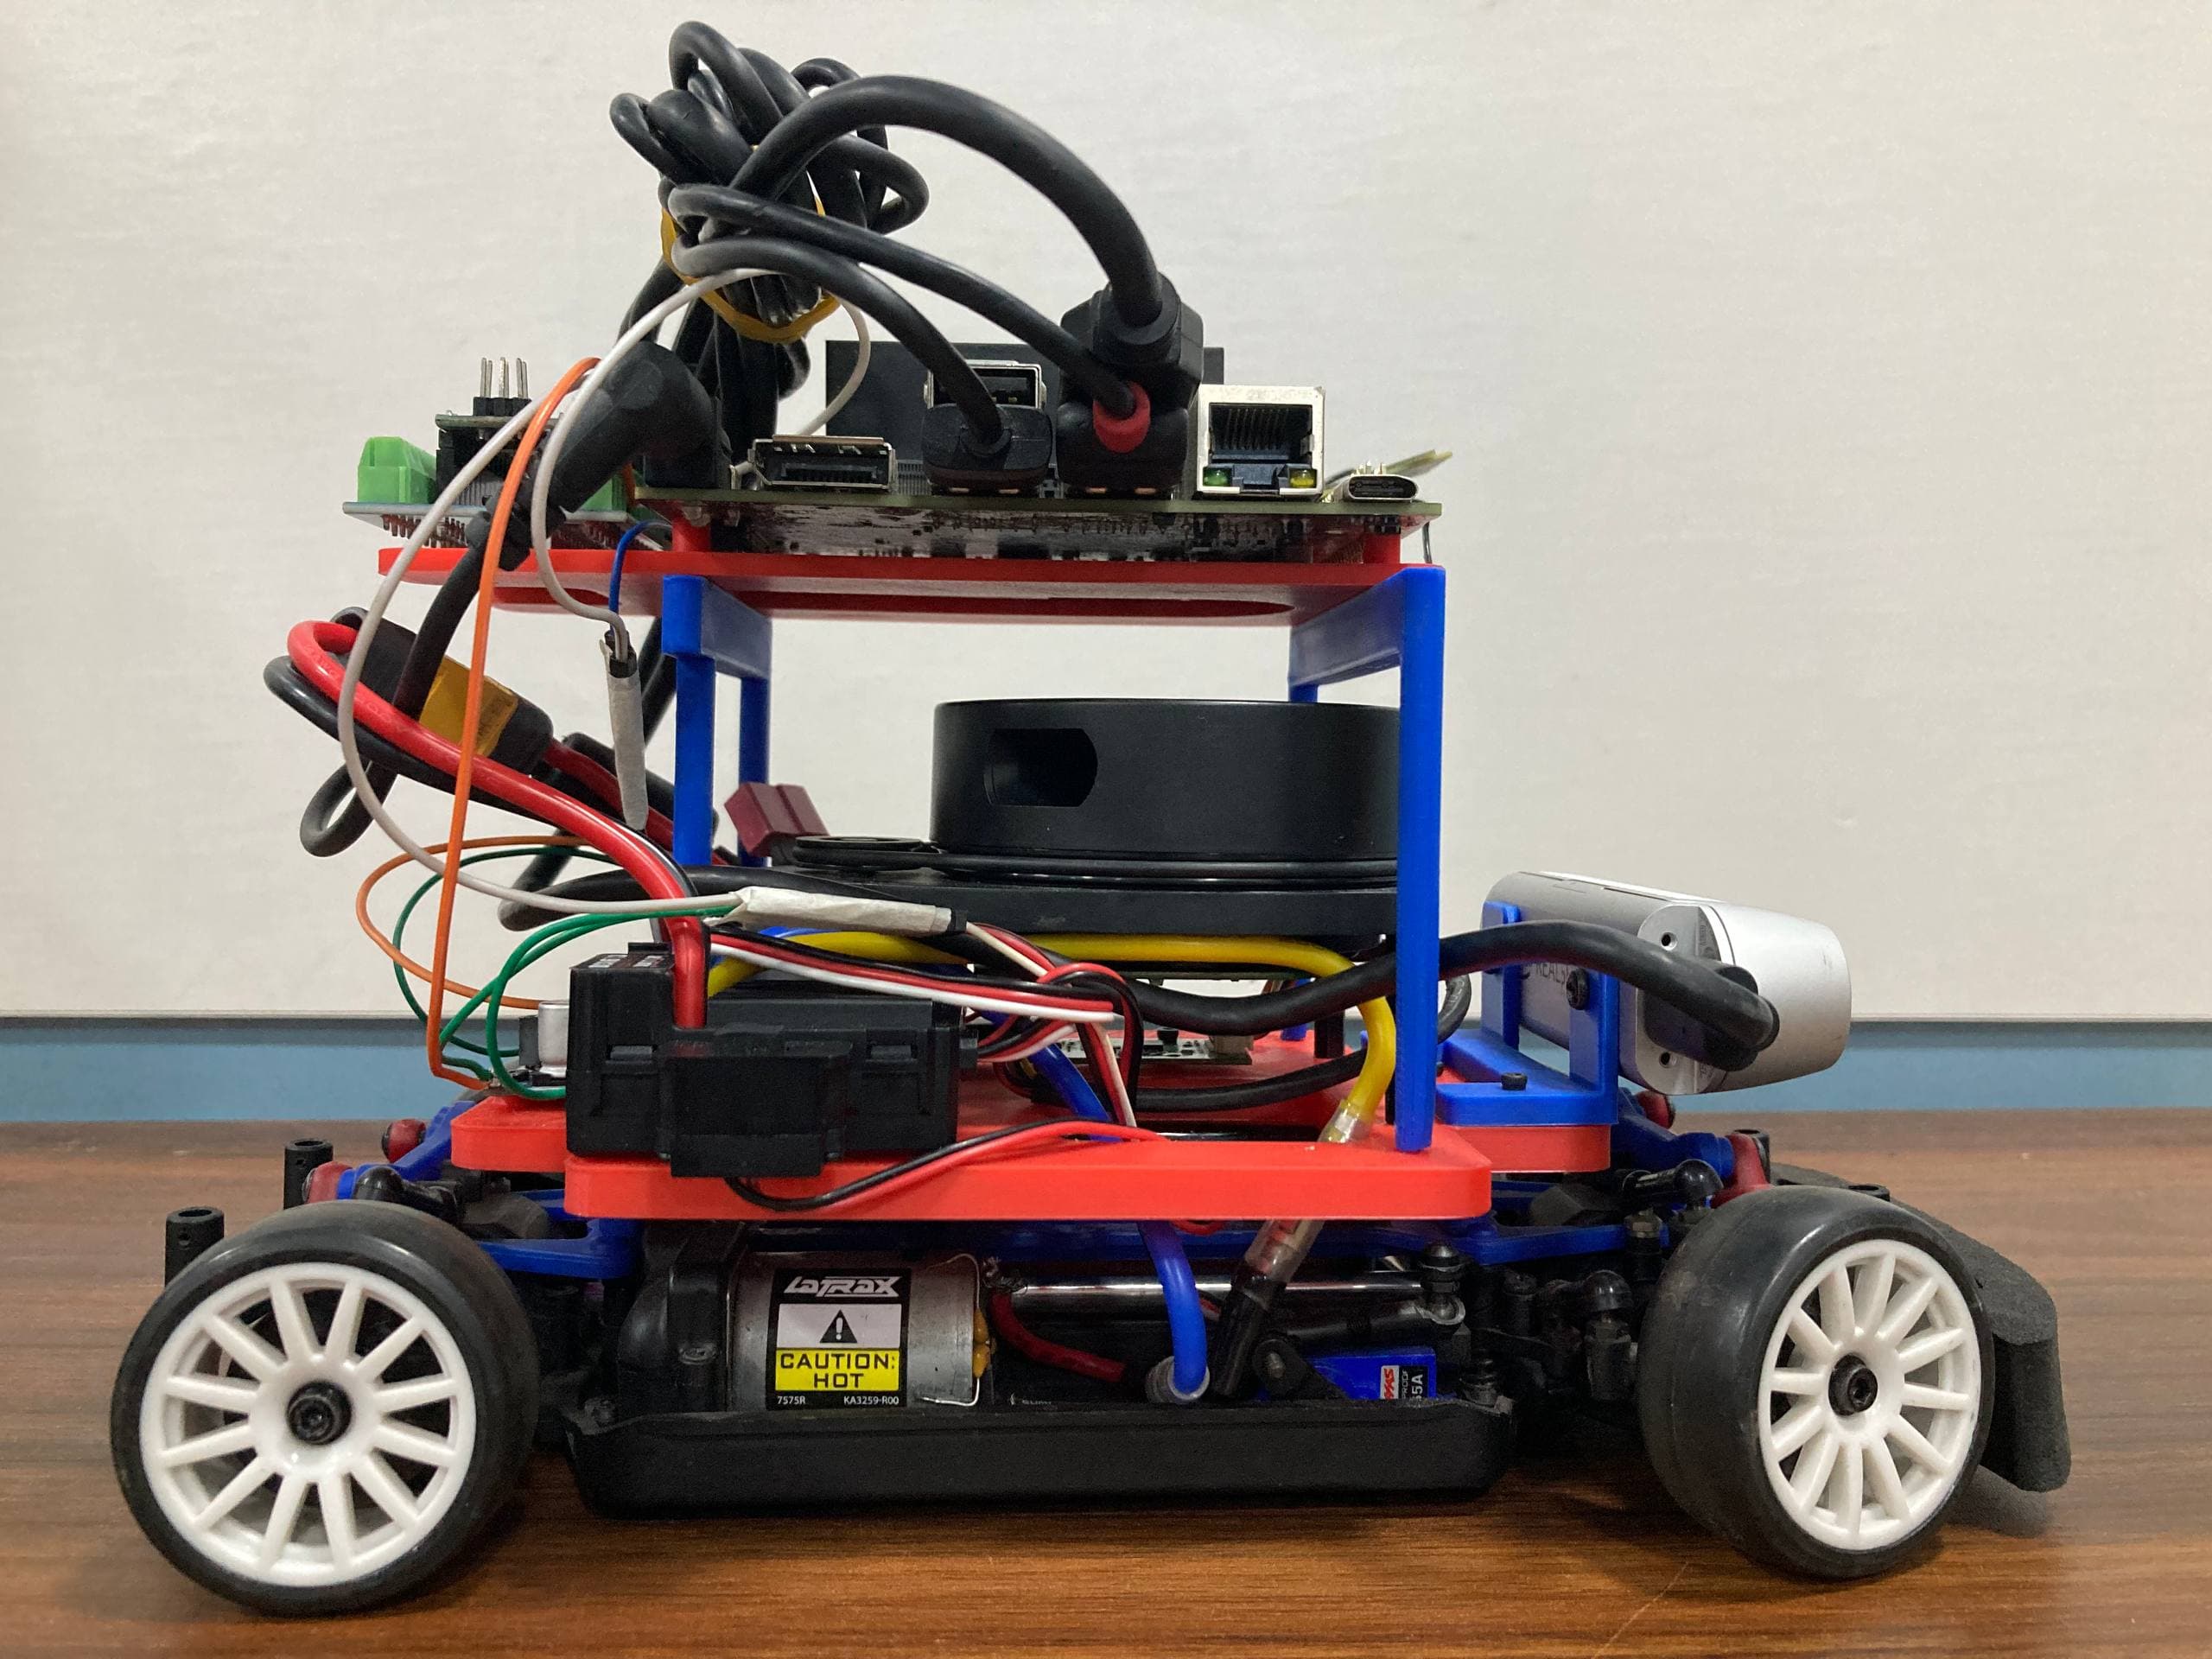
A radio-controlled car rebuilt to drive itself, entered in the World Robotics Olympiad 2025 in Ghana, where it mapped the course and avoided obstacles with nobody at the controls. It fuses LiDAR with an Intel RealSense depth camera on an NVIDIA Jetson Orin Nano, and closes the loop on steering and speed with PID control.